
Free online engineering tools for electric machine drives: PI current controller design for PMSM, IPMSM, EESM, and induction motors, alongside power electronics, thermal analysis, and EV propulsion calculators.
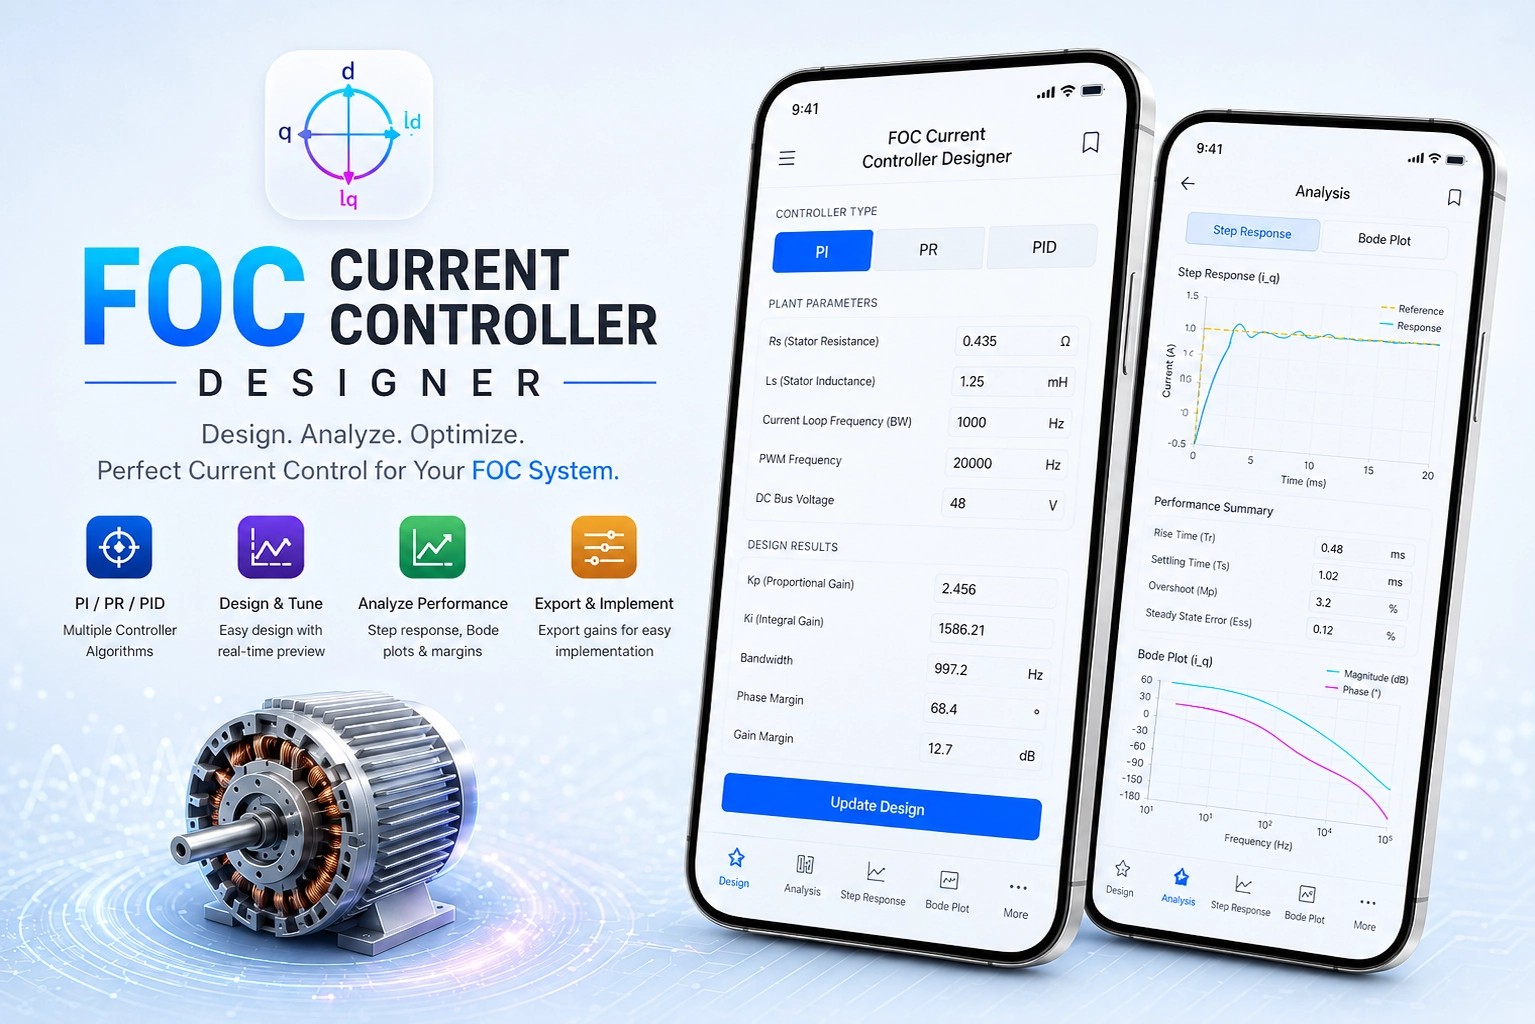
Design PI current controllers in the frequency domain for AC electric machine drives. Features stability analysis, Bode plots, and embedded C-code generation. Supports EESM, IPMSM, and Induction Motors.
Coming Soon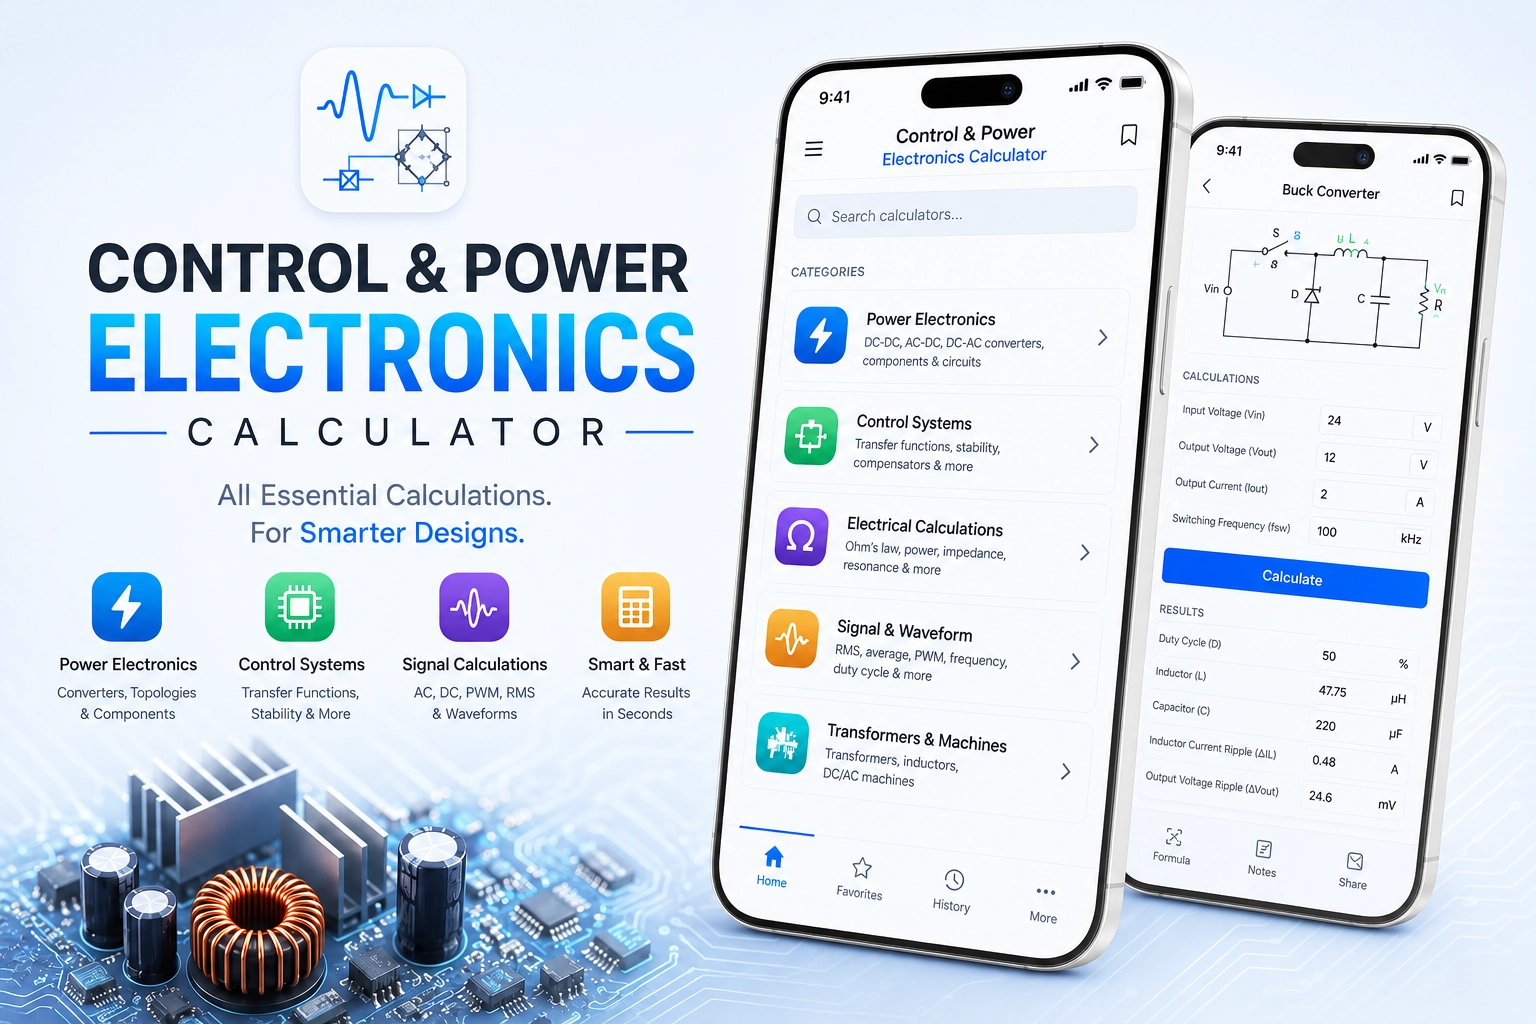
A practical engineering calculator covering motor control, power electronics, embedded firmware, thermal analysis, and EV propulsion. Includes PMSM/IPMSM/EESM torque models, SVPWM, PI controller design, Buck/Boost converters, thermal rise, and road load calculations.
Coming SoonHands-on Raspberry Pi tutorials covering GPIO, PWM dimming, ACS712 current sensing with the ADS1263 32-bit ADC HAT, closed-loop PI and finite-horizon MPC current control of a MOSFET driver, and a real-time UDP scope receiving from a TI F28388D controlCARD.
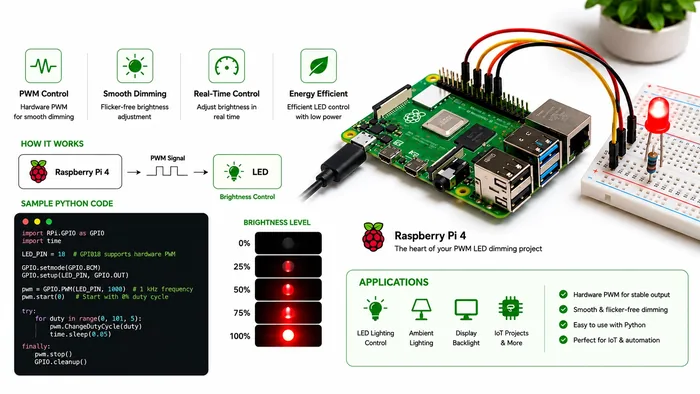
A hands-on introduction to GPIO output and digital signals. Wire up an LED, write a Python script, and control it directly from the Pi's GPIO pins, the classic starting point for hardware programming.
Beginner
Use Pulse Width Modulation to smoothly control LED brightness from software. A practical demonstration of how PWM bridges the gap between digital outputs and analog-like control, which is the basis for motor drives and power converters.
Beginner-Intermediate
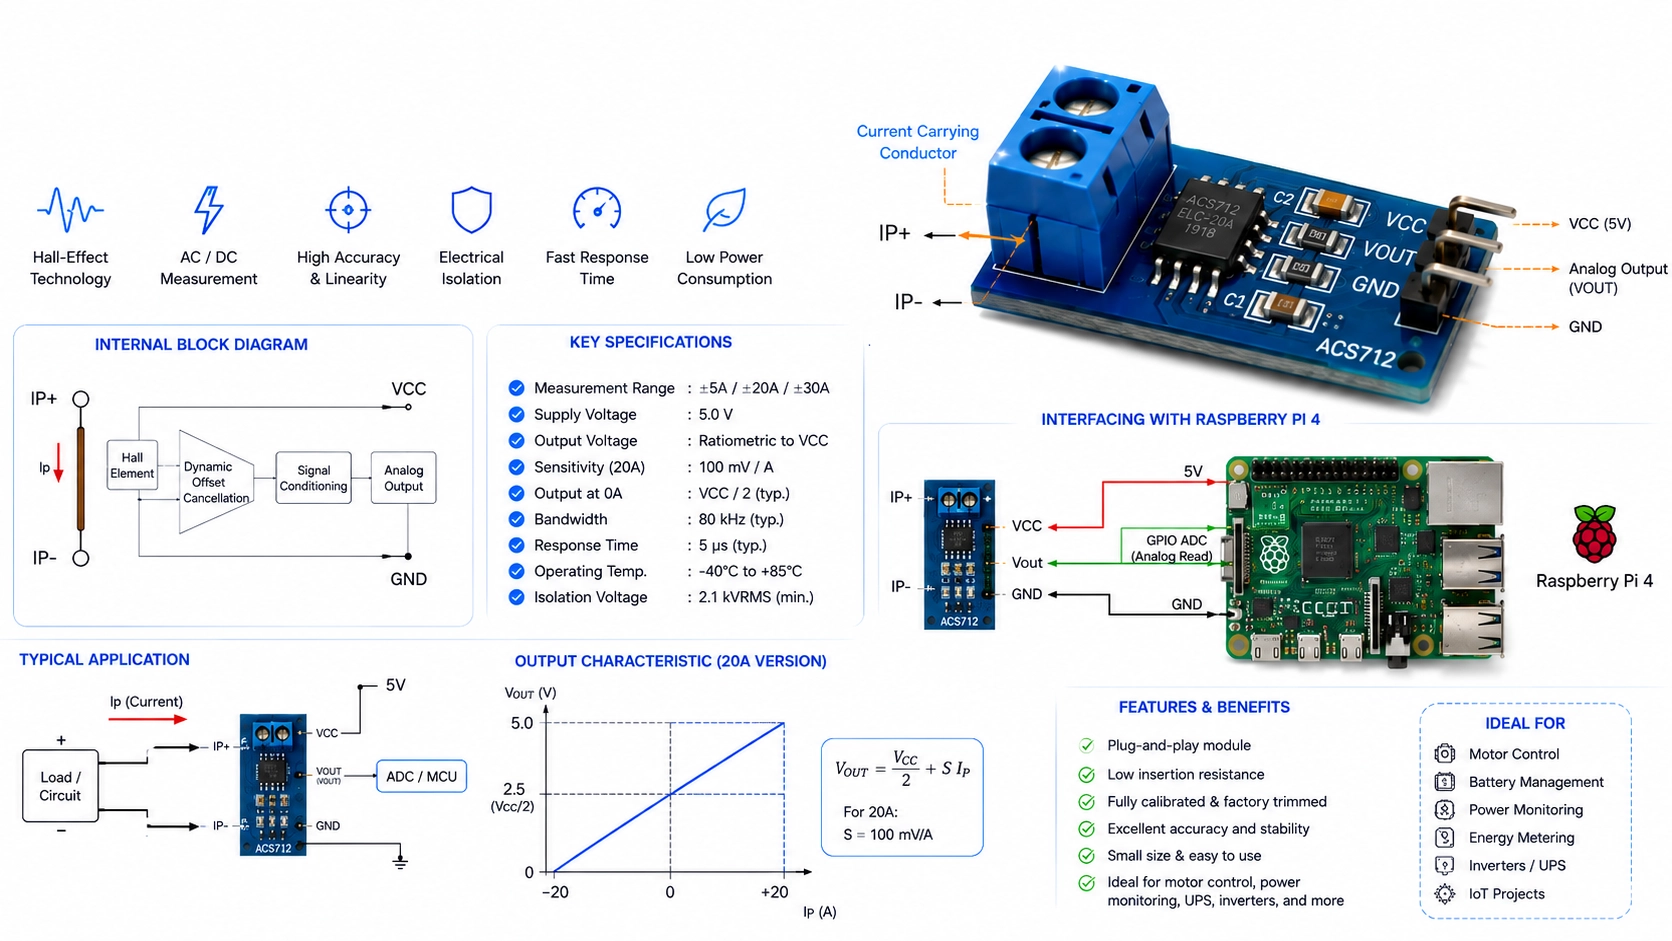
Read real DC/AC current using an ACS712 hall-effect sensor and the ADS1263 32-bit ADC HAT over SPI. Covers differential measurement, SPI communication, and converting raw ADC counts to engineering units.
Intermediate
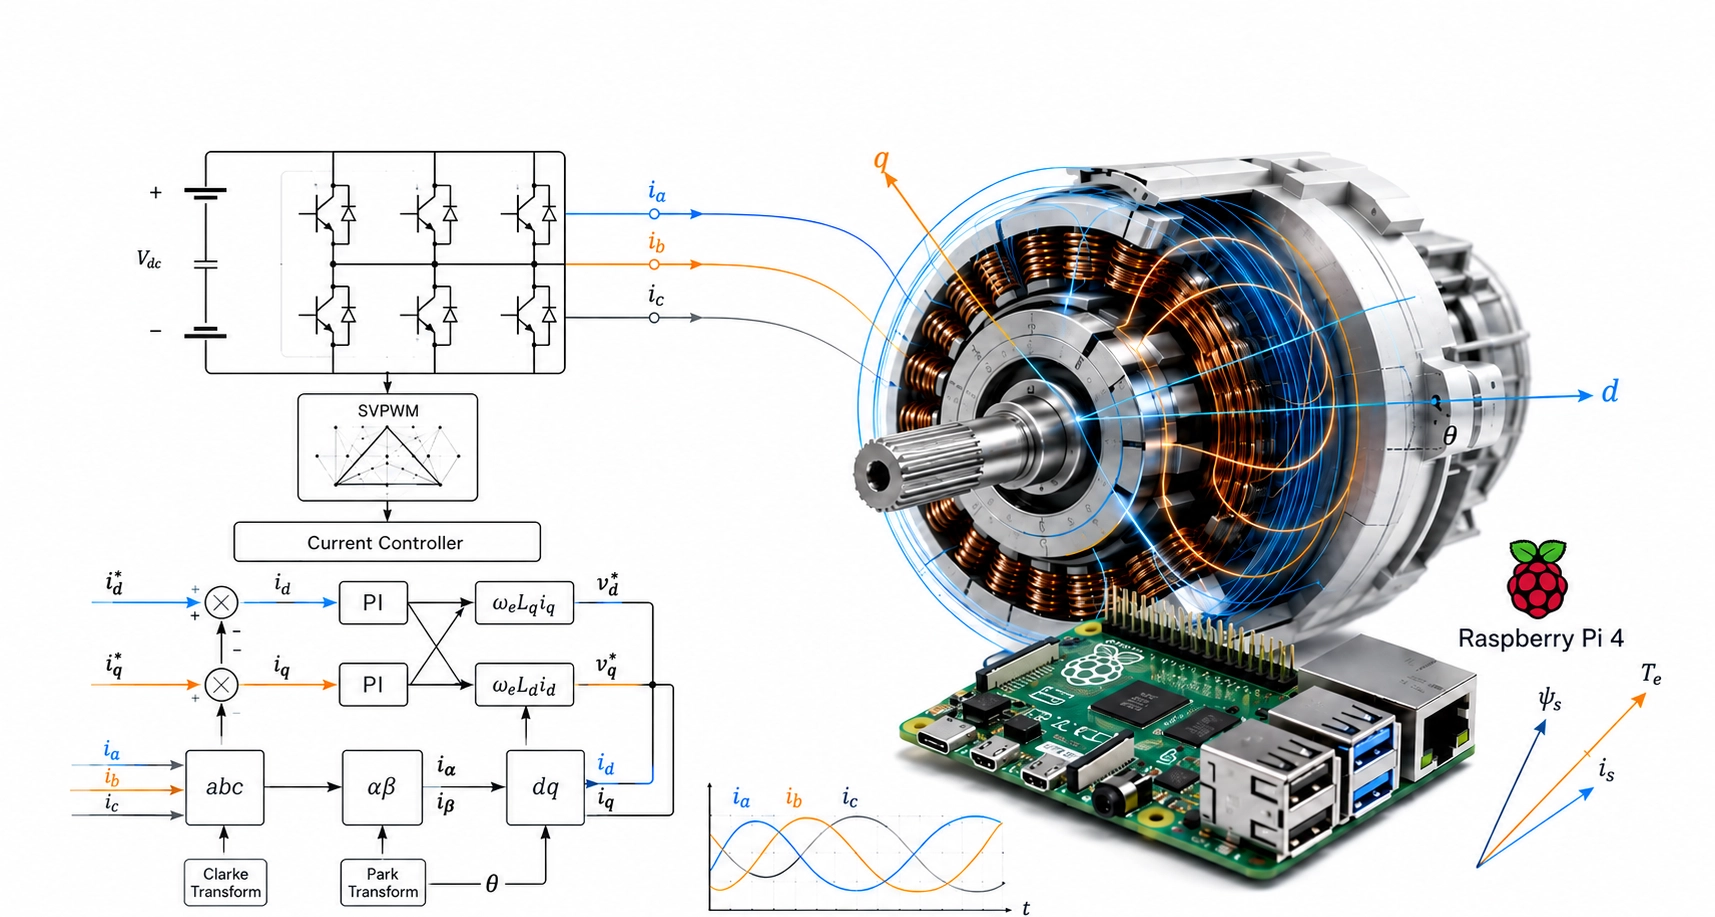
A complete closed-loop PI current controller running on the Pi. The D4184 MOSFET switches a resistive load while the ACS712 feeds current feedback, a real-world demonstration of the same control loop used in industrial power electronics.
Intermediate-Advanced
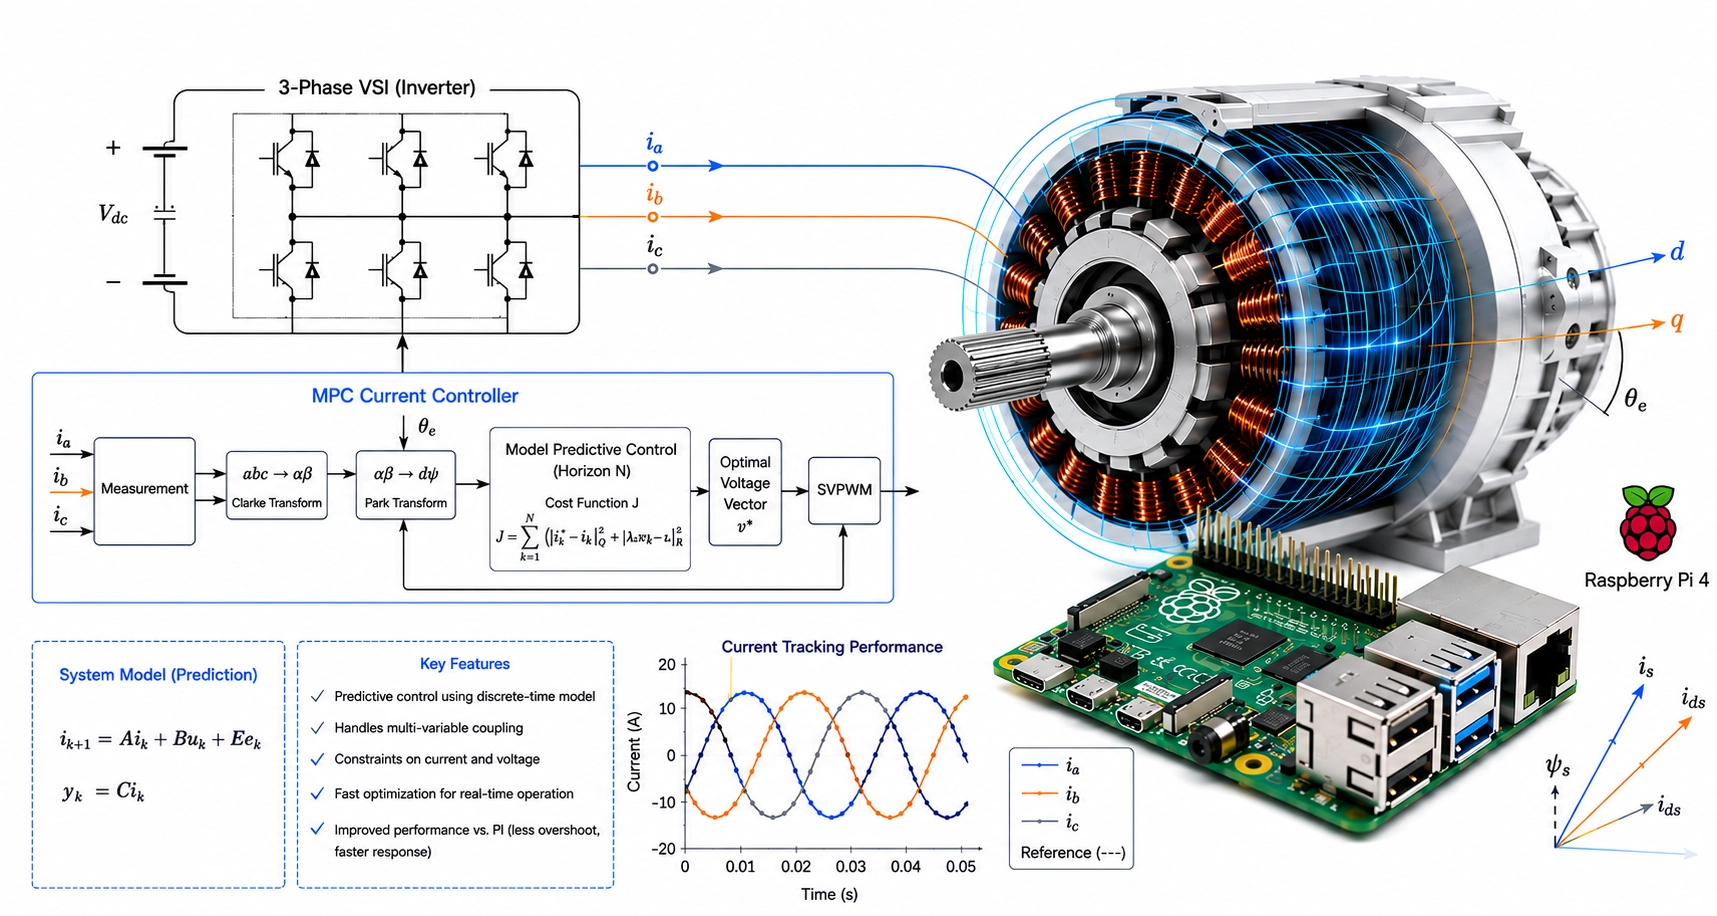
A finite-horizon constrained Model Predictive Controller on the same MOSFET and ACS712 hardware as project 04. Identifies the plant model online from a step test, precomputes the optimal gain matrix, and runs a full constrained optimization at ~480 Hz with no manual tuning required.
Advanced
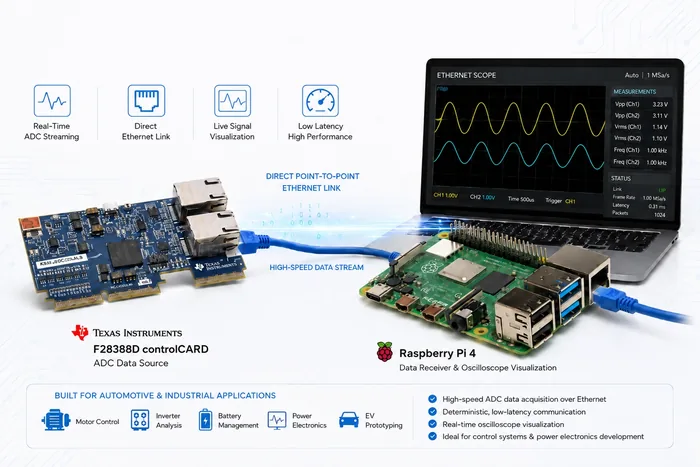
Receives the F28388D controlCARD ADC stream over a direct point-to-point Ethernet link and renders it as a live oscilloscope. ADCINA0 is sampled at 10 kHz on the controlCARD and shipped in 50-sample UDP packets at 200 packets/s, holding zero loss over multi-minute windows. The Pi runs a threaded UDP listener feeding a bounded ring buffer, exposed through two consumers: a CLI sniffer for bring-up diagnostics, and a Streamlit + Plotly dashboard with live KPIs (current, mean, min, max, RMS, packet rate, loss %, link uptime), pause toggle, and CSV export. The binary packet parser is the single source of truth, hand-aligned byte for byte against the firmware sender.
Advanced
Pi-side command and visualization host for the F28388D synchronous-frame current controller on a 48 V GaN inverter. The Pi sends binary command packets at 200 Hz over UDP (Id/Iq references, electrical-frequency, plant parameters, enable/reset) and receives 5 kHz telemetry on a second port. A four-panel Streamlit + Plotly dashboard renders Id/Iq reference vs measurement, three phase currents, and DC-bus voltage, with a live status decoder for overcurrent and watchdog flags. CRC-16-CCITT on every packet. Full design notes in the GitHub README.
Advanced
Firmware on the TI F28388D dual-core C28x DSP with the BOOSTXL-3PhGaNInv 48 V GaN inverter: GPIO blink, three-phase SVPWM with synchronized ADC, discrete PI current control on the CLA coprocessor, CMPSS hardware overcurrent protection, lwIP Ethernet streaming, and synchronous-frame field-oriented current control over UDP.
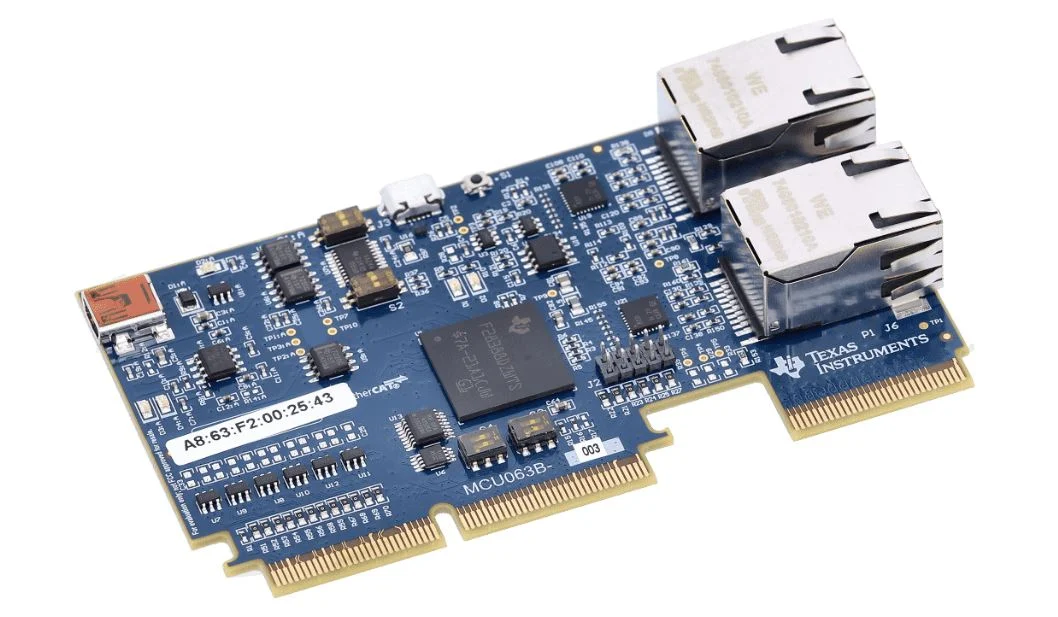
Hardware bring-up verification for the TMDSCNCD28388D controlCARD. Blinks the onboard D1 LED at 1 Hz via GPIO31, confirming the clock tree, GPIO subsystem, and JTAG debug connection are all working before any application firmware is deployed.
Beginner
Generates three-phase Space Vector PWM at 20 kHz on the BOOSTXL-3PHGANINV inverter board using ePWM1/2/3 with dead-time insertion. The ADC fires synchronously at the PWM carrier peak to sample at the minimum current ripple point, while a dedicated CLA task reads the result in parallel with the main CPU. Sector, duty cycles, and ADC data stream to UART at 10 Hz.
Intermediate–Advanced
A 20 kHz PI current controller running entirely on the F28388D CLA coprocessor, leaving the main C28x CPU free for reference generation and UART telemetry. Gains are designed from bandwidth targets (ωc = 2π×1000 rad/s) and discretised in incremental form, giving natural anti-windup with no extra logic. The CLA task finishes in under 2 µs, triggered by the ADC conversion complete interrupt, and writes the new duty cycle to shared message RAM for the ePWM ISR. A companion Python script reads 10 Hz serial telemetry and plots the measured Bode response against the theoretical open-loop curve.
Advanced
Hardware overcurrent protection for a GaN inverter leg using the F28388D CMPSS and ePWM Trip Zones. The comparator checks phase current against ±8 A thresholds entirely in hardware, tripping ePWM1 outputs to zero in under 100 ns with no CPU involvement. A 32-sample digital filter blanking window rejects switching transient noise. Both CBC and OST trip modes are supported, a Trip Zone ISR logs fault events in a 16-entry circular buffer, and 10 Hz UART telemetry streams current and fault data at 115200 baud. A software fault injection test runs automatically on startup to verify the protection path end to end.
Advanced
Dual-core firmware that turns the F28388D into an Ethernet-attached scope front-end. The C28x CPU1 samples ADCINA0 at 10 kHz (ePWM1 SOCA triggering ADC-A SOC0), converts each result to volts, and publishes into a 128-deep float ring in shared MSGRAM. The Cortex-M4 Connectivity Manager runs lwIP NO_SYS on the on-chip Ethernet MAC at static IP 192.168.10.10, polls the ring on a 1 ms SysTick, and packs 50 samples per UDP datagram at 200 packets/s. CPU1 boots the CM core via Device_bootCM in the strict flash order required by the F2838x dual-core protocol. Verified end to end against a Raspberry Pi receiver with zero packet loss over multi-minute windows.
Advanced
Field-oriented current controller for a three-phase RL load on the BOOSTXL-3PhGaNInv 48 V GaN inverter, commanded over Ethernet by a Raspberry Pi 4. CPU1 runs the 20 kHz Clarke → Park → dual PI → inverse Park → SVPWM pipeline inside the ADCA1 EOC ISR (closes in ~4.5 µs of the 50 µs switching period). IMC pole-zero gains, back-calculation anti-windup, feed-forward cross-axis decoupling, and a hardware safety layer (overcurrent, over/under voltage, Ethernet watchdog). The Cortex-M4 core runs lwIP NO_SYS and bridges two UDP sockets to CPU1 through MSGRAM mailboxes. CRC-16-CCITT on every packet. Full design notes in the GitHub README.
Advanced
Python and Matplotlib animations of motor control fundamentals: Space Vector PWM principle, Clarke and Park transformations, dq-current decoupling for PMSM, PLL-based back-EMF observer at low speed, a complete FOC loop with disturbance observer, and complex-vector PI versus conventional PI under frequency sweep.
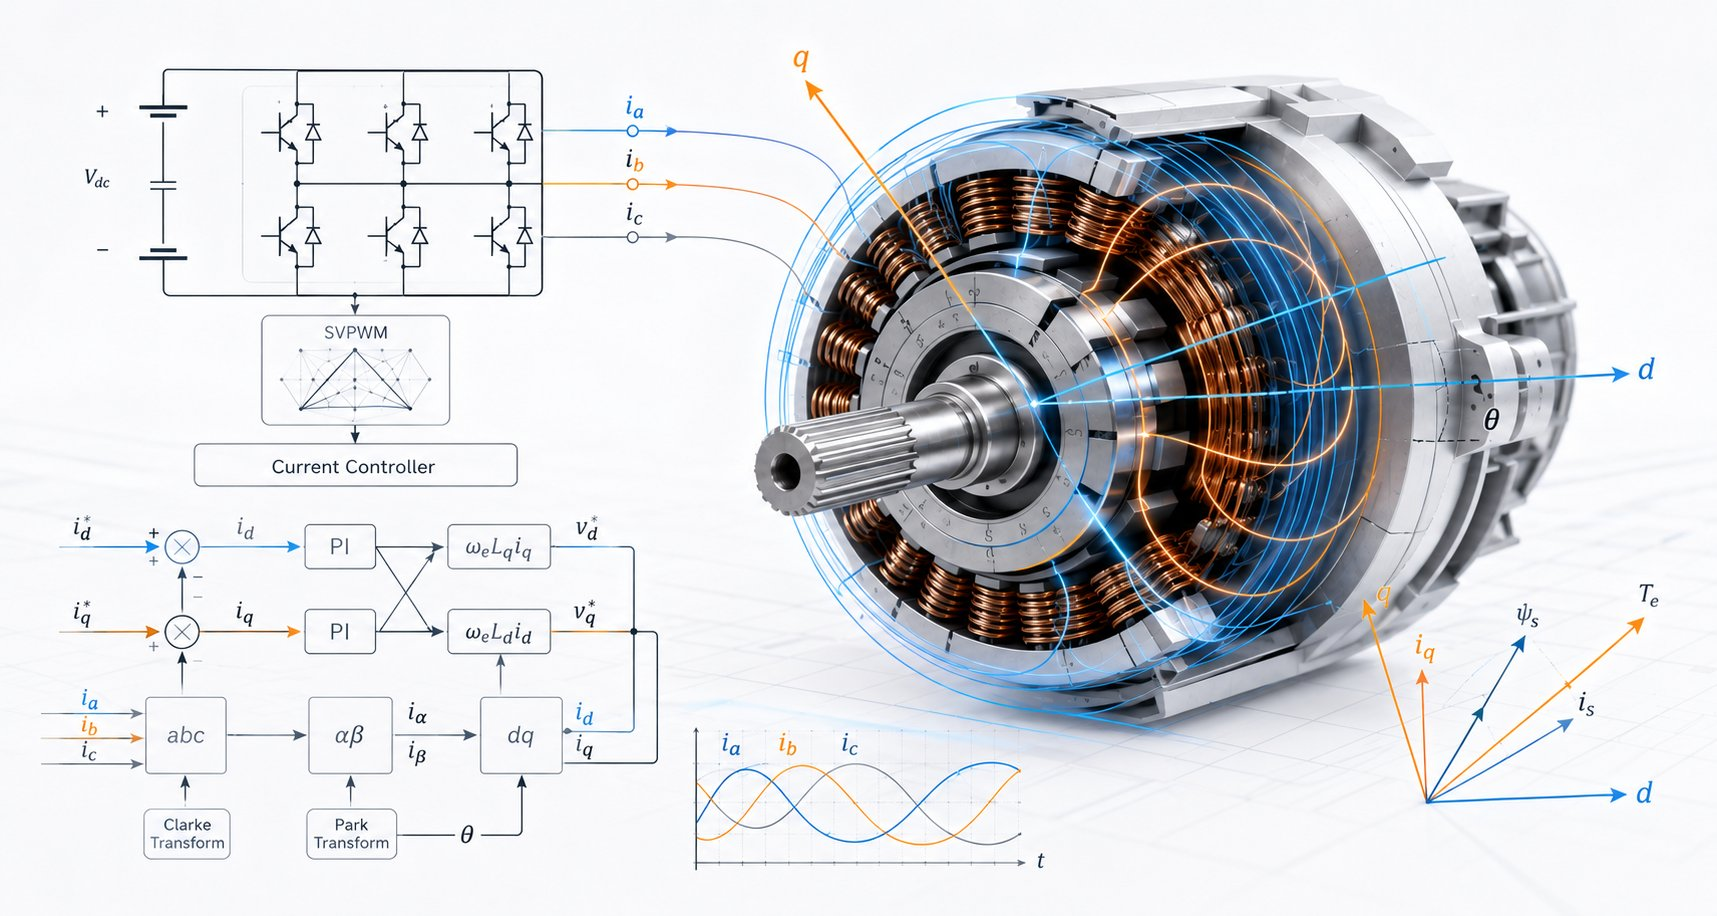
Crystal-clear animation showing how SVPWM builds its 7-segment inverter switching pattern from a rotating voltage reference vector.
0:59
Visual walkthrough of the Clarke (αβ) and Park (dq) transforms that sit at the heart of field-oriented motor control.
0:58
Animation showing how d-axis and q-axis current decoupling works in PMSM field-oriented control and why it is essential for independent torque and flux regulation.
Simulation showing how a PLL-based observer tracks the back-EMF angle in a PMSM as speed approaches zero, highlighting phase error and loss of lock near standstill.
Full closed-loop PMSM FOC simulation with real-time load torque disturbance observer and live signal visualization across the entire control chain.
Side-by-side comparison of synchronous-frame complex-vector PI and conventional PI on an RL load as electrical frequency sweeps 0-200 Hz, with Bode plots at key operating points.
Recent developments in electric drive engineering, EV traction motors, SiC and GaN inverters, 800 V architectures, solid-state batteries, and machine learning for motor control and condition monitoring.
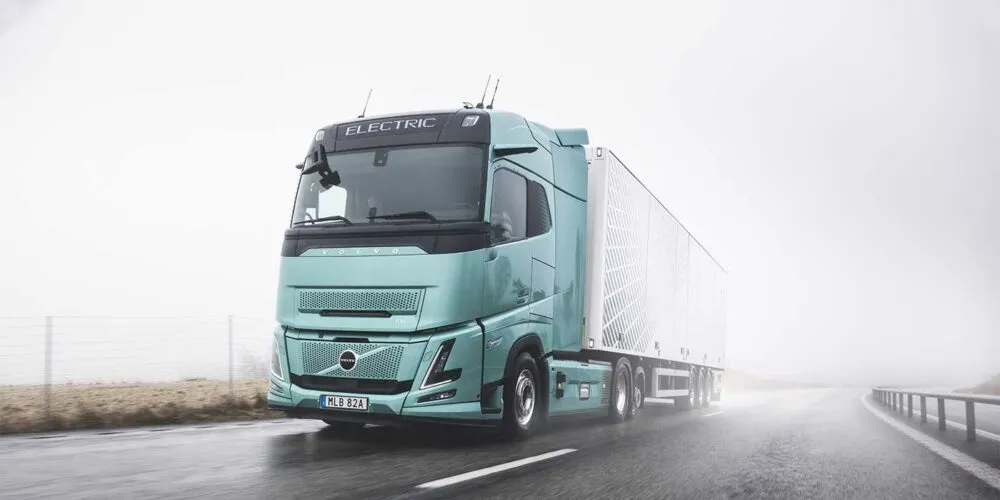
Volvo's global heavy-duty electric lineup took the top prize of the IAA Transportation press day in Hannover. International Truck of the Year 2027 went to the four-model electric family, the FH Electric, FM Electric, FMX Electric, and FH Aero Electric, built on the same global platform and launched for export markets this year. The 24-member international jury called out the combination the industry has been chasing for a decade: a long enough range to compete with diesel on real duty cycles, a wide enough application set to cover long-haul, regional, construction, and distribution from one chassis, high overall energy efficiency, and operational flexibility that lets fleets run the same truck as a 4x2 tractor, a 6x2 rigid, or a construction prime mover. This is Volvo's eighth ITOY win overall and the second specifically for the FH Electric, which already took the title in 2024 and is the first battery-electric heavy truck to win the award twice. On the same evening Renault swept the Van of the Year category and ZF picked up the components award, which puts the three European award winners on the Volvo Group side of the show floor and locks in battery-electric heavy-duty as the mainstream platform for the next ITOY cycle.
Oct 2026
Read More »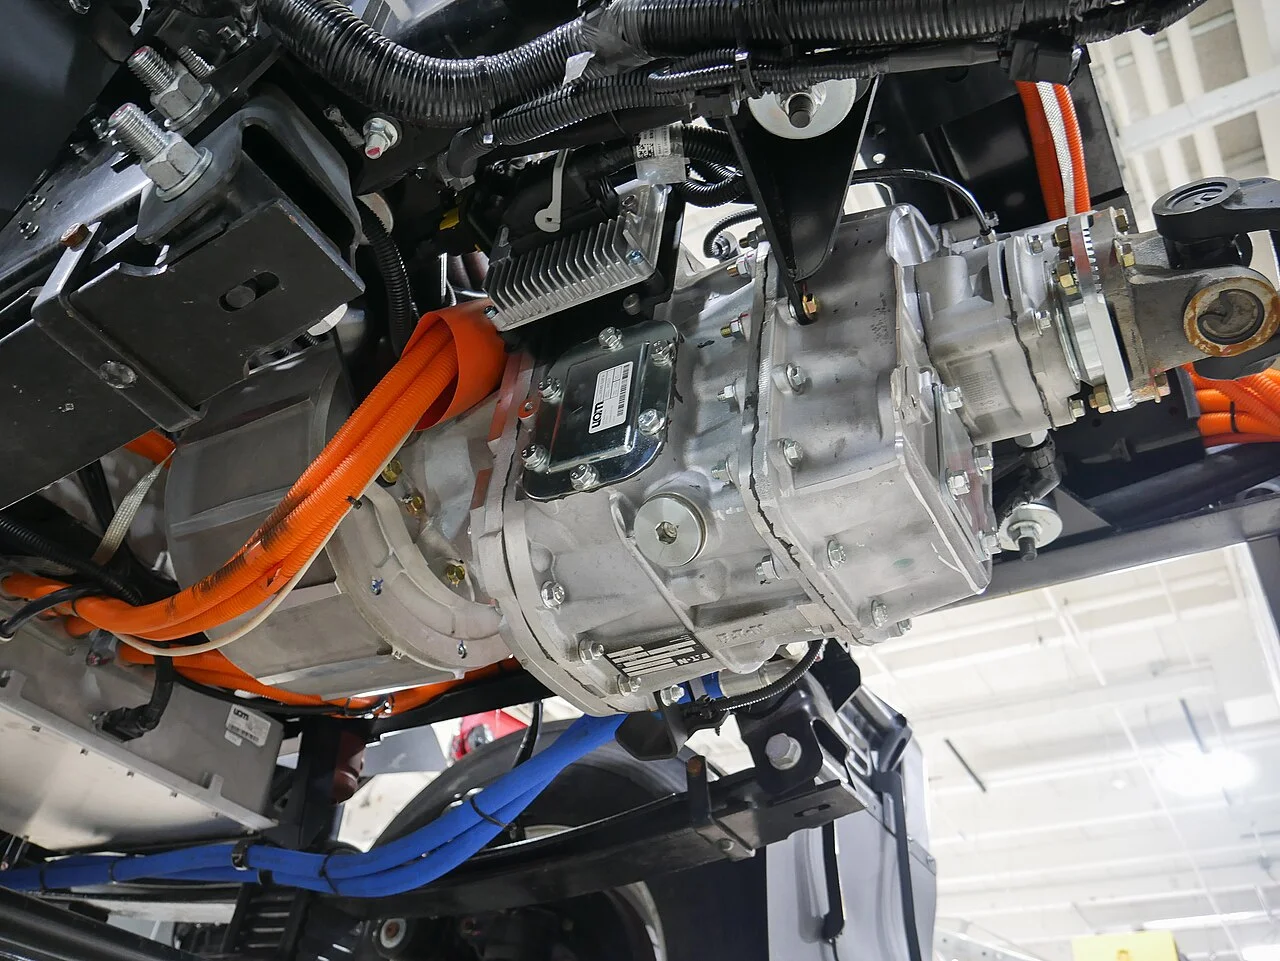
MAHLE used IAA Transportation to put a rare-earth-free alternative on the heavy-duty traction map. The new MAHLE Contactless Transmitter (MCT) motor is a wound-rotor synchronous machine with no permanent magnets anywhere in the rotor and therefore no neodymium, dysprosium, or terbium content in the drive. Rotor excitation is handed over wirelessly instead of through slip rings or brushes, which is the piece that gives the motor its name and takes the usual wear item of an externally excited machine out of the drivetrain. Peak output is 370 kW and over 900 Nm on a drive-axle duty cycle, VECTO efficiency reaches 95 percent, and the whole motor is up to 10 kg lighter than a comparable magnet machine. For an engineer speccing a heavy-duty e-axle the three practical consequences are that supply-chain exposure to the Chinese magnet market disappears, end-of-life recycling cost drops because the rotor is standard copper and iron, and field weakening at highway speed becomes a current-reference problem on the rotor side rather than a magnet-flux problem on the stator side. MCT is one of two MAHLE world premieres on this stand; the second is a range-extender module aimed at pushing BEV trucks past 800 km of total range on a single platform.
Oct 2026
Read More »
Tesla used IAA Transportation to finally commit to a European launch for the Semi and to put real specifications on the table rather than another concept lap. The European Semi runs on a rear-axle architecture that mounts three independent traction motors instead of a single large machine, with combined drivetrain output up to 800 kW. Range is quoted at up to 550 km, specific energy consumption at 1.0 kWh per kilometre, and DC fast charging is rated to recover roughly 60 percent of pack energy in about 30 minutes on the Megacharger infrastructure Tesla is building out alongside the vehicle. European customer deliveries are targeted for 2027. The interesting piece for a motor-control engineer is the three-motor topology: splitting traction across three machines turns torque vectoring into a software problem on the rear axle, lets Tesla run smaller individual rotors at higher base speeds, and converts single-motor derating under thermal load into a graceful degradation across three thermal paths instead of a hard limit. This is the clearest signal yet that distributed e-axle motor architectures, previously limited to performance passenger cars, are moving into mainstream Class 8 trucking.
Oct 2026
Read More »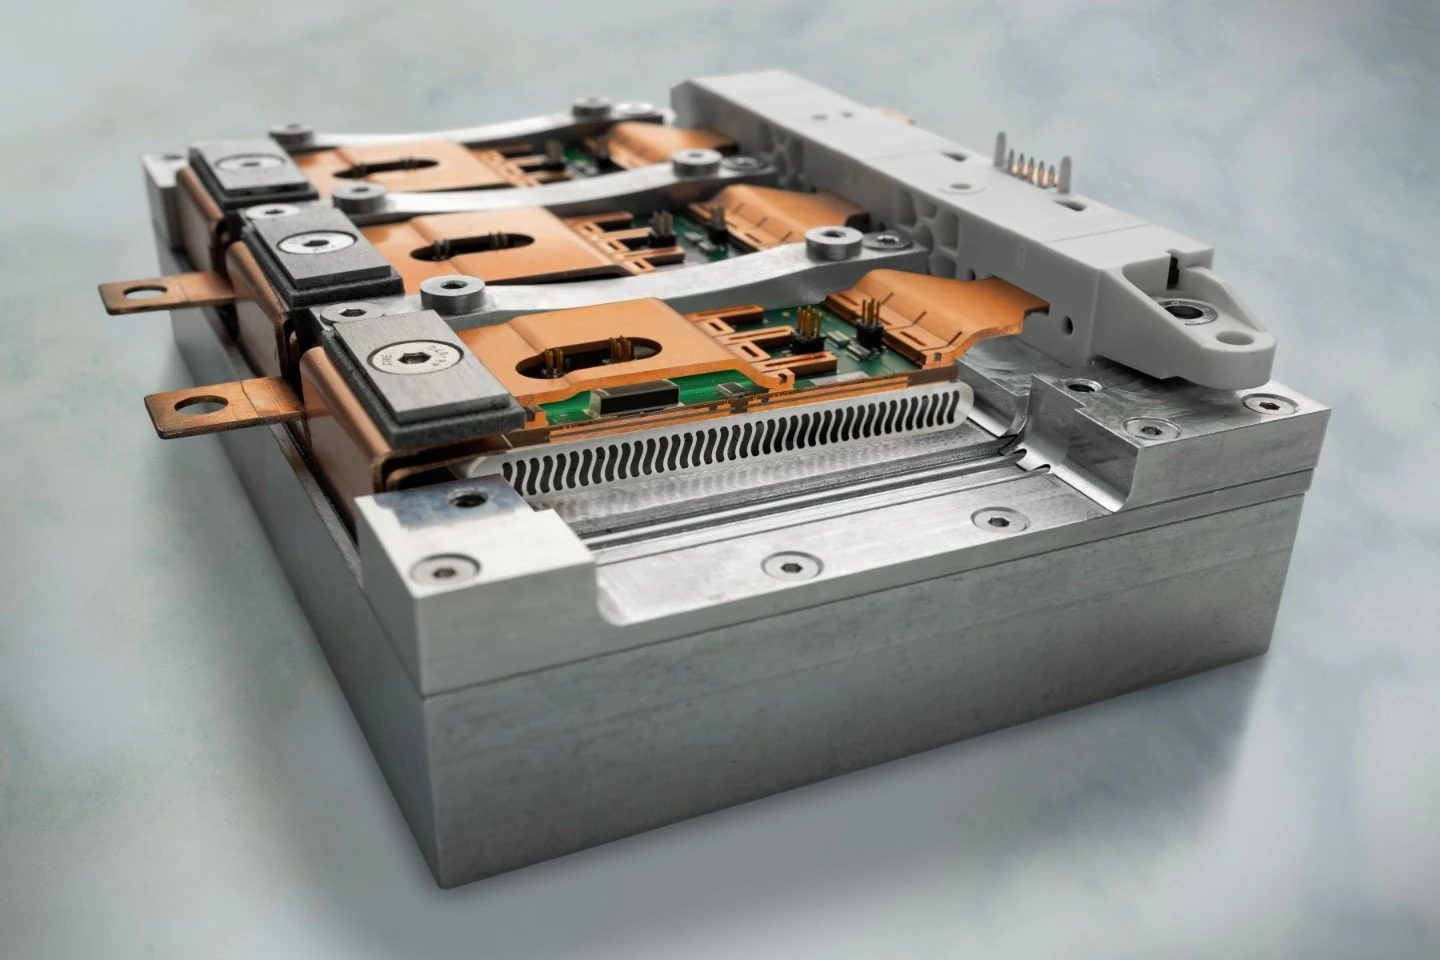
onsemi introduced the Embedded Power Platform (EPP) this week, an architecture that abandons the discrete-die approach that has defined power modules for decades and treats the wafer itself as the package. The idea is straightforward on paper and hard in practice: co-integrate silicon, silicon carbide, and gallium nitride dies together with their gate drivers inside a single bonded structure, then use the wafer as the electrical and thermal substrate. onsemi is claiming up to 4x the power density of conventional traction-inverter builds and about 15 percent lower switching and conduction losses, both driven by the tighter loop inductances and shorter thermal paths that fall out when the wire bonds between chip, driver, and copper are removed. For a 400 V or 800 V EV traction inverter, that translates into either a smaller box for the same continuous torque or higher continuous torque without going up in area, and it removes one of the biggest reliability failure modes at the die-package interface. The platform is aimed first at automotive traction and AI-datacenter power delivery, but the same construction is what a compact FOC drive for industrial motors needs to move above 100 kHz switching without a copper-bus problem. It is the strongest signal so far that wide-bandgap traction is heading toward wafer-scale integration rather than a smarter discrete assembly.
Sep 2026
Read More »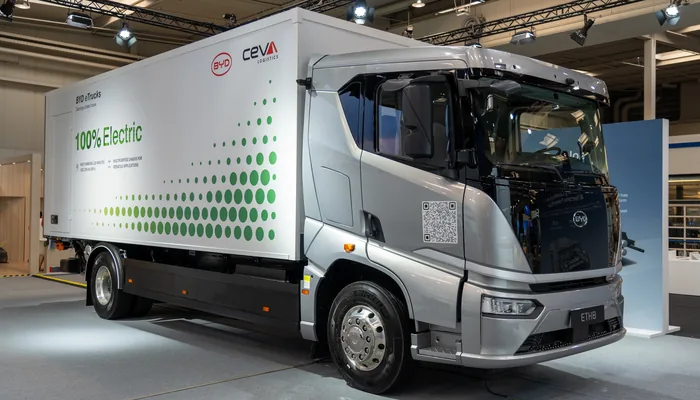
BYD used IAA Transportation this week to move its heavy-duty electric truck story out of China and into the European long-haul market, and the specs are the kind that reset the ceiling for what a battery-electric tractor is supposed to do. The new ETT 44 is a 4x2 tractor designed for combinations up to 44 tonnes, built on an 851 V bus with a 651 kWh Blade Battery, rated 743 PS with peak power up to 1000 PS and around 600 km of range. The interesting number for a power electronics engineer is the DC input side: on a standard CCS2 charger the ETT 44 pulls up to 420 kW and takes 20 to 80 percent in about an hour, but plugged into BYD's own Megawatt Charging System it takes more than 1.5 MW and does the same 20 to 80 percent in roughly 20 minutes, adding up to 400 km of range in that window. BYD is not selling the truck by itself either; it is packaging the vehicle with its Blade cells, megawatt chargers, stationary storage, energy management, and financing under a Total Cost of Mobility model that spans a 3.5 to 44 tonne battery-electric lineup. This is the first time a European heavy-duty electric drive customer can spec a mainstream tractor around megawatt-class DC infrastructure from a single supplier.
Sep 2026
Read More »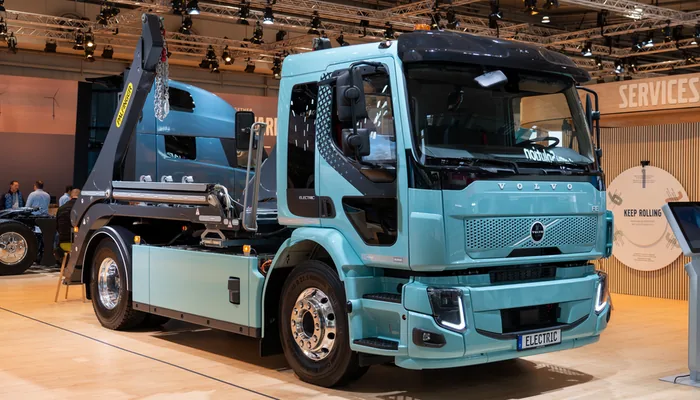
Turntide arrived at IAA Transportation in Hannover this week with three integrated axial flux products that finally push the topology out of hypercars and into refuse trucks, cement mixers, cranes, and lifts. The headline is the new axial flux Electric Drive Unit, a semi-integrated package that keeps motor, inverter, and differential inside one housing with shared cooling and a simplified gearset. Against a radial flux drive of similar output, Turntide is quoting 53 percent higher torque density, 58 percent less volume, and 37 percent less weight, on a modular platform that scales from 55 kW all the way to 1 MW. Alongside it, an electric power take-off in 50, 100, and 150 kW variants targets equipment with a lot of idle time, running at above 90 percent peak system efficiency, and a hybrid configuration extends the same axial flux hardware into diesel-plus-electric commercial platforms. The EDU has already logged more than 600 miles at the 2026 King of the Hammers, which is a real duty cycle for a first press-day announcement. This is the moment axial flux stops being a European hypercar curiosity and starts appearing on the drive-unit spec sheets for mainstream commercial fleets.
Sep 2026
Read More »Plan22 is an engineering practice focused on motor control: field-oriented control (FOC), PMSM and IPMSM electric machine drives, inverter systems, and automotive control software.
Plan22 is where engineering tools, Python simulations, and hands-on hardware projects live, built at the intersection of motor control, power electronics, and EV systems.
Here you will find FOC current controllers running on TI C2000 DSP, Python tools that size PI gains from machine parameters, and hardware demos that go from Raspberry Pi GPIO basics to a dual-core synchronous-frame drive over Ethernet.
For inquiries or collaboration, send us a message or fill out the form below:
info@plan22.net